Autonomy · Safe Control · Robot Perception

Robots that estimate, plan and act — under real constraints.

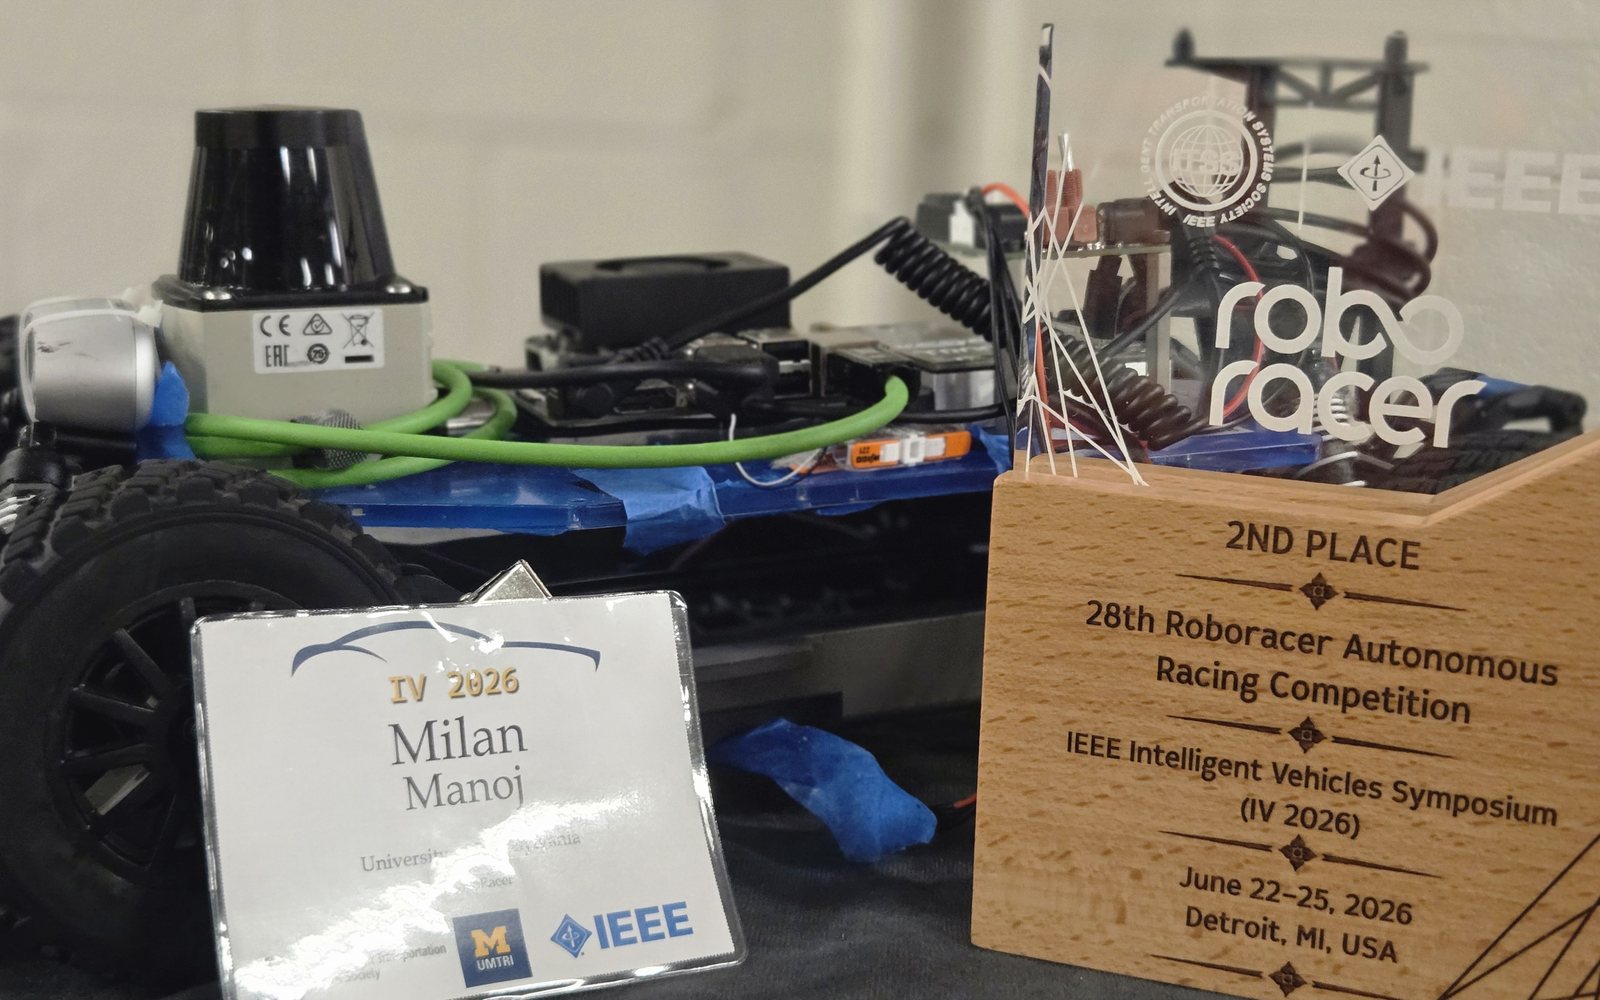
I'm a robotics engineer and M.S.E. student at the University of Pennsylvania, working where estimation, planning and control have to hold up on real hardware. At GRASP I own the ground autonomy for the DARPA Triage Challenge; at xLab I work on safe learning-based MPC that learns its own terminal constraints. I also TA Penn's autonomous racing course — and took 2nd at Roboracer with the stack I built for it.

2nd
Roboracer 2026
3.90
GPA at Penn
7
Publications
Portrait of Milan Manoj
Philadelphia, PA

01 — About

End-to-end roboticist.

I build autonomy stacks end to end — estimation, planning, control and the perception that feeds them — and I care most about the seams where those pieces meet, because that is where real robots fail. Right now that means ground autonomy over unstructured terrain at GRASP, safe learning-based MPC at xLab, and a Frenet-frame nonlinear MPC that races a 1/10-scale car at the limits of grip.

I'm drawn to problems where a cleaner formulation beats a bigger model: collapsing three disagreeing heuristics into one terrain model, learning an invariant set rather than assuming a model of the dynamics, or finding the 4x parameter error that was costing more lap time than any amount of solver tuning would. I'm looking for research and engineering roles in autonomy, safe control and robot perception.
Languages

PythonC++CJavaJavaScriptHTMLCSS

Robotics & ML

ROSROS 2NAV2acadosCasADiHPIPMCVXPYMediaPipePyTorchTensorFlowOpenCV

Tools

DockerLinuxGitFlaskSpring BootAngular

Databases

PostgreSQLMySQL

02 — Experience

Where I've worked.

University of Pennsylvania

Teaching Assistant — ESE 6150, F1TENTH Autonomous Racing

Fall 2026

Philadelphia, PA, USA

  • TA for Penn's graduate autonomous racing course: weekly ROS 2 labs, F1TENTH hardware bring-up, office hours, and grading of labs and final race projects.

xLab for Safe Autonomous Systems

Research Assistant (Part-time) · University of Pennsylvania

Jul 2026 – Present

Philadelphia, PA, USA

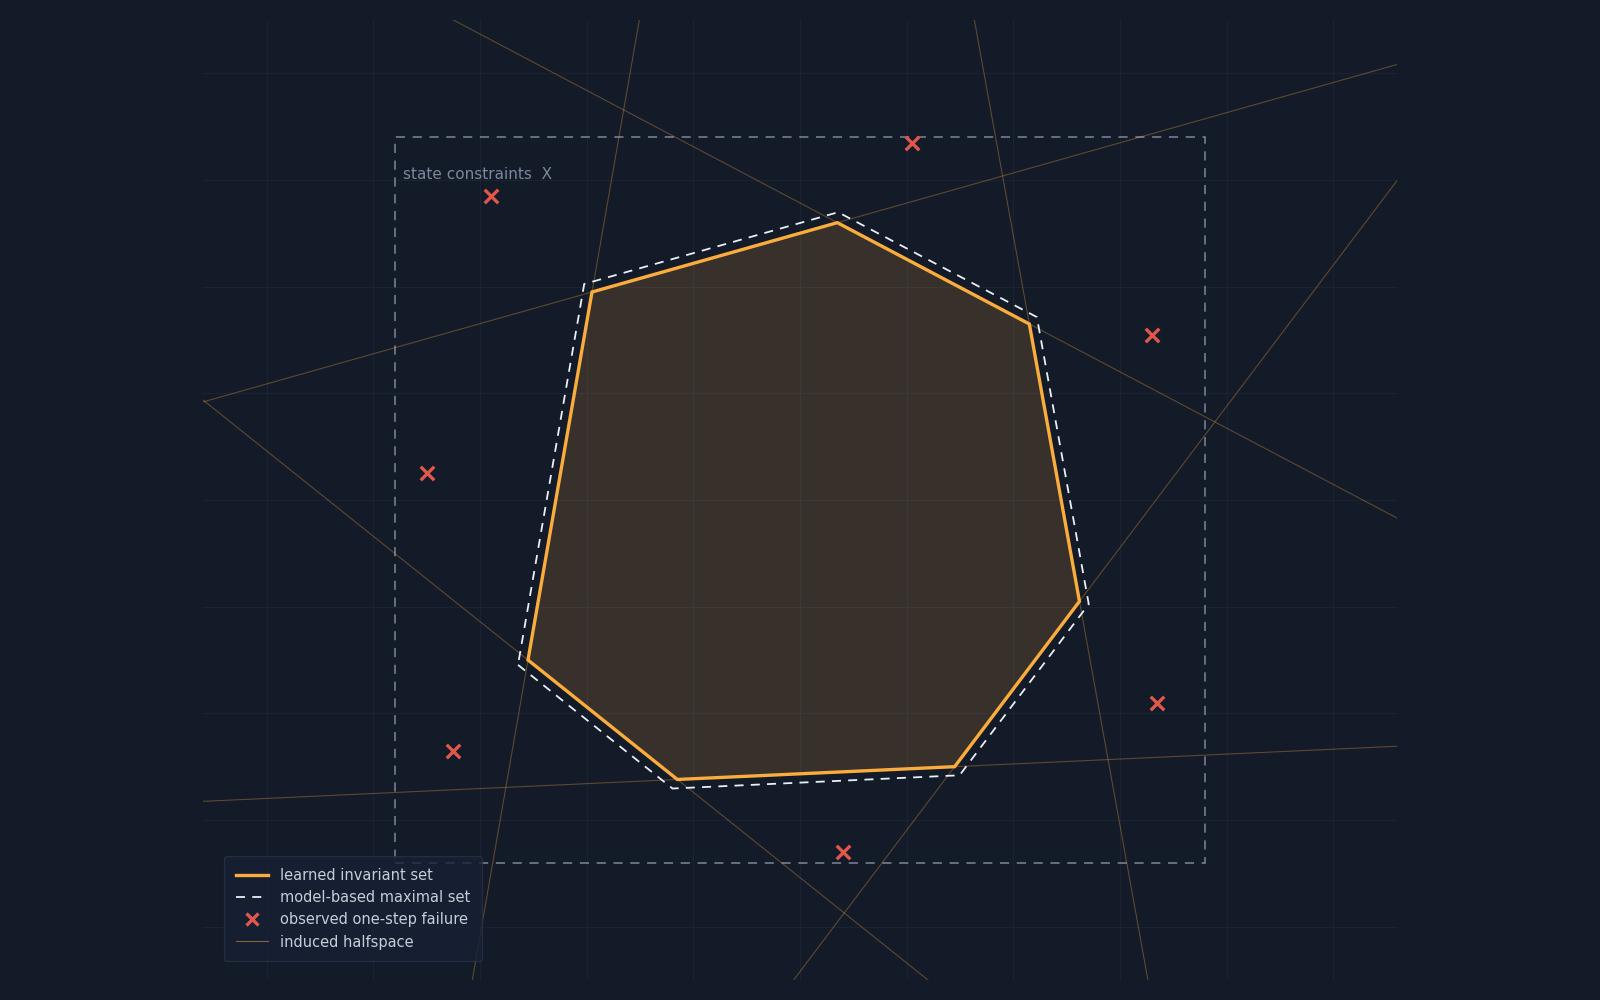
  • Safe Learning-Based MPC: developing a Failure-Aware Iterative Learning (FAIL) pipeline that learns state-control invariant sets from observed one-step failures, used as MPC terminal constraints without any model of the dynamics.
  • Building the halfspace-learning and model-free certification loop in NumPy/SciPy/CVXPY; currently recovers the model-based maximal invariant set to under 1e-15 support-function error on 10/10 seeds in ~5 s.
  • Benchmarking MPC terminal-set formulations in closed loop: the learned set stays recursively feasible at N = 1, where plain MPC loses feasibility and a zero terminal set is infeasible until N = 12.
  • Smart Brain Biopsy System: developing a medical robotics pipeline converting MRI/CT scans into patient-specific 3D anatomical meshes for surgical planning.
  • Implementing trajectory and probe insertion planning for an AR-guided robotic biopsy system, integrating imaging data with surgical visualization tools.

GRASP Lab

Research Assistant (Part-time) · University of Pennsylvania

Jan 2026 – Present

Philadelphia, PA, USA

  • DARPA Triage Challenge: sole developer of the autonomy driving a Clearpath Jackal goal-to-goal through unstructured outdoor terrain — adapted a spline-based aerial planner to a ground robot, reusing only its Hermite-spline trajectory representation and writing the 4.5K-line C++ / ROS 2 planner around it.
  • Built the planning and control loop: A* over a live traversability grid with footprint inflation and clearance shaping, safe-corridor extraction and spline optimization, and a Kanayama spline-tracking controller with curvature-based speed capping, slew limiting and stuck/boxed-in recovery.
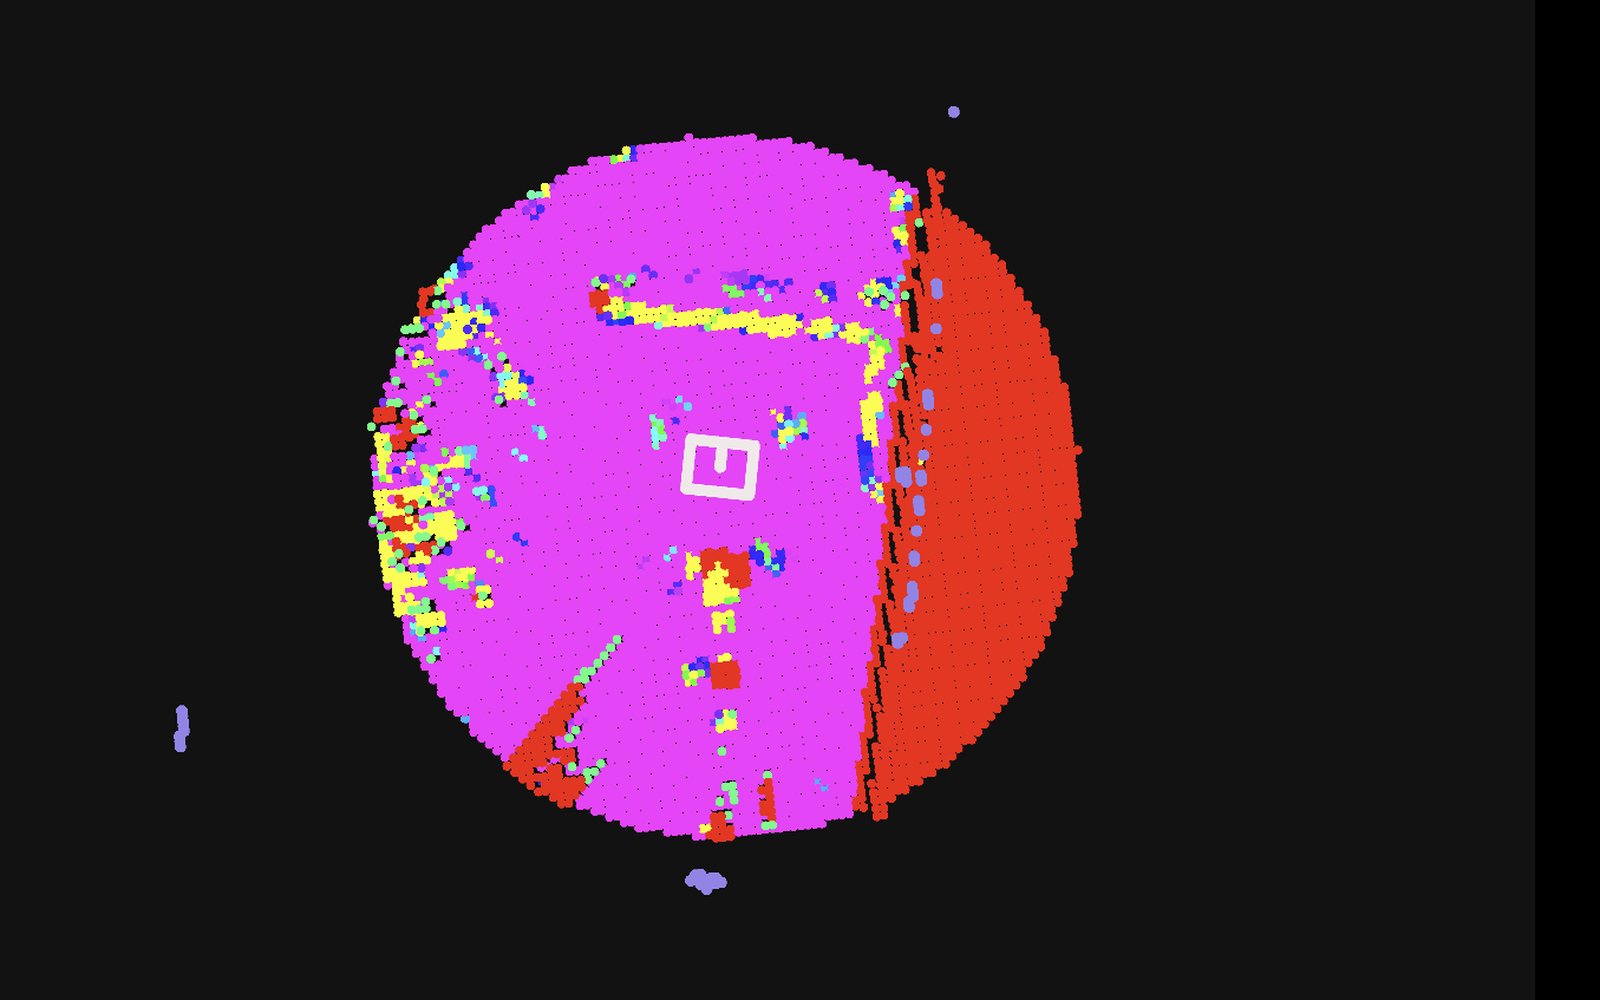
  • Replaced three inconsistent step-height heuristics with a single terrain model reducing the LiDAR elevation map to per-cell traversability and wheel-geometry speed limits — adding curb, gutter and negative-obstacle detection plus a point-cloud layer for thin objects the elevation map smooths away.
  • Replaced a per-cell logistic-regression terrain classifier with a 1.5M-parameter BEV U-Net over LiDAR (RELLIS-3D + on-robot data), raising mIoU from 25 to 63 and road IoU from 0.00 to 0.86; exported to ONNX at ~32 ms/scan and wired into per-surface controller gain switching.

Amrita Vishwa Vidyapeetham

Software Developer Intern

Sept 2023 – May 2024

India

  • Built a Python OCR pipeline processing 15,000+ research PDFs at 90% structured-data accuracy.
  • Developed an NL-to-SQL clinical query system using LLMs and Flask, reducing clinician SQL dependency by 85%.
  • Created a Flask + Gemini question-generation tool with Bloom's taxonomy tagging and PostgreSQL storage.

03 — Projects

Selected work.

Research and course projects across autonomy, safe control, racing, state estimation and applied ML. Click any project for the full write-up.

04 — Publications

Peer-reviewed work.

Seven publications spanning clinical decision support, medical imaging and applied machine learning — five as first author.
  1. [01]2025

    Interactive Multimedia System for Granuloma Annulare Classification: Integrating Transformer Neural Networks with Clinical Decision Support↗

    Manoj, M., Rajan, A., Sreekumar, V., Anjali, T., Abhishek, S.

    IEEE MultiMedia · doi:10.1109/MMUL.2025.3624322

  2. [02]2025

    AI in Sperm Evaluation

    Manoj, M., Sankar, P., Fernandes, I., Figueiredo, D.

    AI-Powered Systems for Healthcare Diagnostics and Treatment · IGI Global — book chapter

  3. [03]2024

    An Extensive Analysis of Breast Cancer Detection using Deep Learning Algorithms↗

    Manoj, M., Rajan, A., Santhosh, G., Anjali, T., Sankar, P.

    3rd Intl. Conf. on Automation, Computing and Renewable Systems (ICACRS) · Pudukkottai, India · pp. 1038–1043 · doi:10.1109/ICACRS62842.2024.10841661

  4. [04]2024

    Machine Learning-Based Detection of Blood Cancer from Microscopic Images: A Comparative Study↗

    Manoj, M., Sreekumar, V., Reghuram, S., Ramlal, N. P.

    9th Intl. Conf. on Communication and Electronics Systems (ICCES) · Coimbatore, India · pp. 2055–2062 · doi:10.1109/ICCES63552.2024.10859403

  5. [05]2024

    Integrating Deep Learning with the Gemini API for Improved Pest Management↗

    Manoj, M., Ihsan, F., Devadath, G. K., Anjali, T.

    3rd Intl. Conf. on Automation, Computing and Renewable Systems (ICACRS) · Pudukkottai, India · doi:10.1109/ICACRS62842.2024.10841572

  6. [06]2024

    An Extensive Analysis of ML Techniques for Predicting and Analysing Medical Data↗

    Rajan, A., Manoj, M., Santhosh, G., Sarath, S.

    5th Intl. Conf. on Electronics and Sustainable Communication Systems (ICESC) · Coimbatore, India · doi:10.1109/ICESC61413.2024.10580451

  7. [07]2023

    Navigating the Effectiveness of Various Machine Learning Algorithms for Myocardial Infarction Prediction

    Rajan, A., Manoj, M., Santhosh, G., Abhishek, S., Anjali, T.

    Intl. Conf. on Intelligent Computing, Communication and Networks (ICI3C)

05 — Education

Academic record.

University of Pennsylvania

School of Engineering and Applied Science

Aug 2025 – May 2027

Philadelphia, PA, USA

M.S.E. in Robotics

GPA 3.90 / 4.00

RoboRacerMachine PerceptionRobot LearningControls and Optimization

Amrita Vishwa Vidyapeetham

School of Computing

Aug 2021 – Aug 2025

India

B.Tech in Computer Science and Engineering

GPA 3.99 / 4.00 · 5th rank in batch

06 — Honors

2nd

28th Roboracer Autonomous Racing Competition (IV 2026)

5th

Rank in B.Tech Computer Science batch (GPA 3.99/4.00)

#1

National Rank, National Science Olympiad (NSO)

07 — Contact

Let's build something that has to work.

I'm open to research collaborations and robotics roles — autonomy, safe control, perception.